This motivates a hierarchical view
p(C1:T | G, τ) ≈ p(s0 | G) · p(C1:T | s0, G, τ)
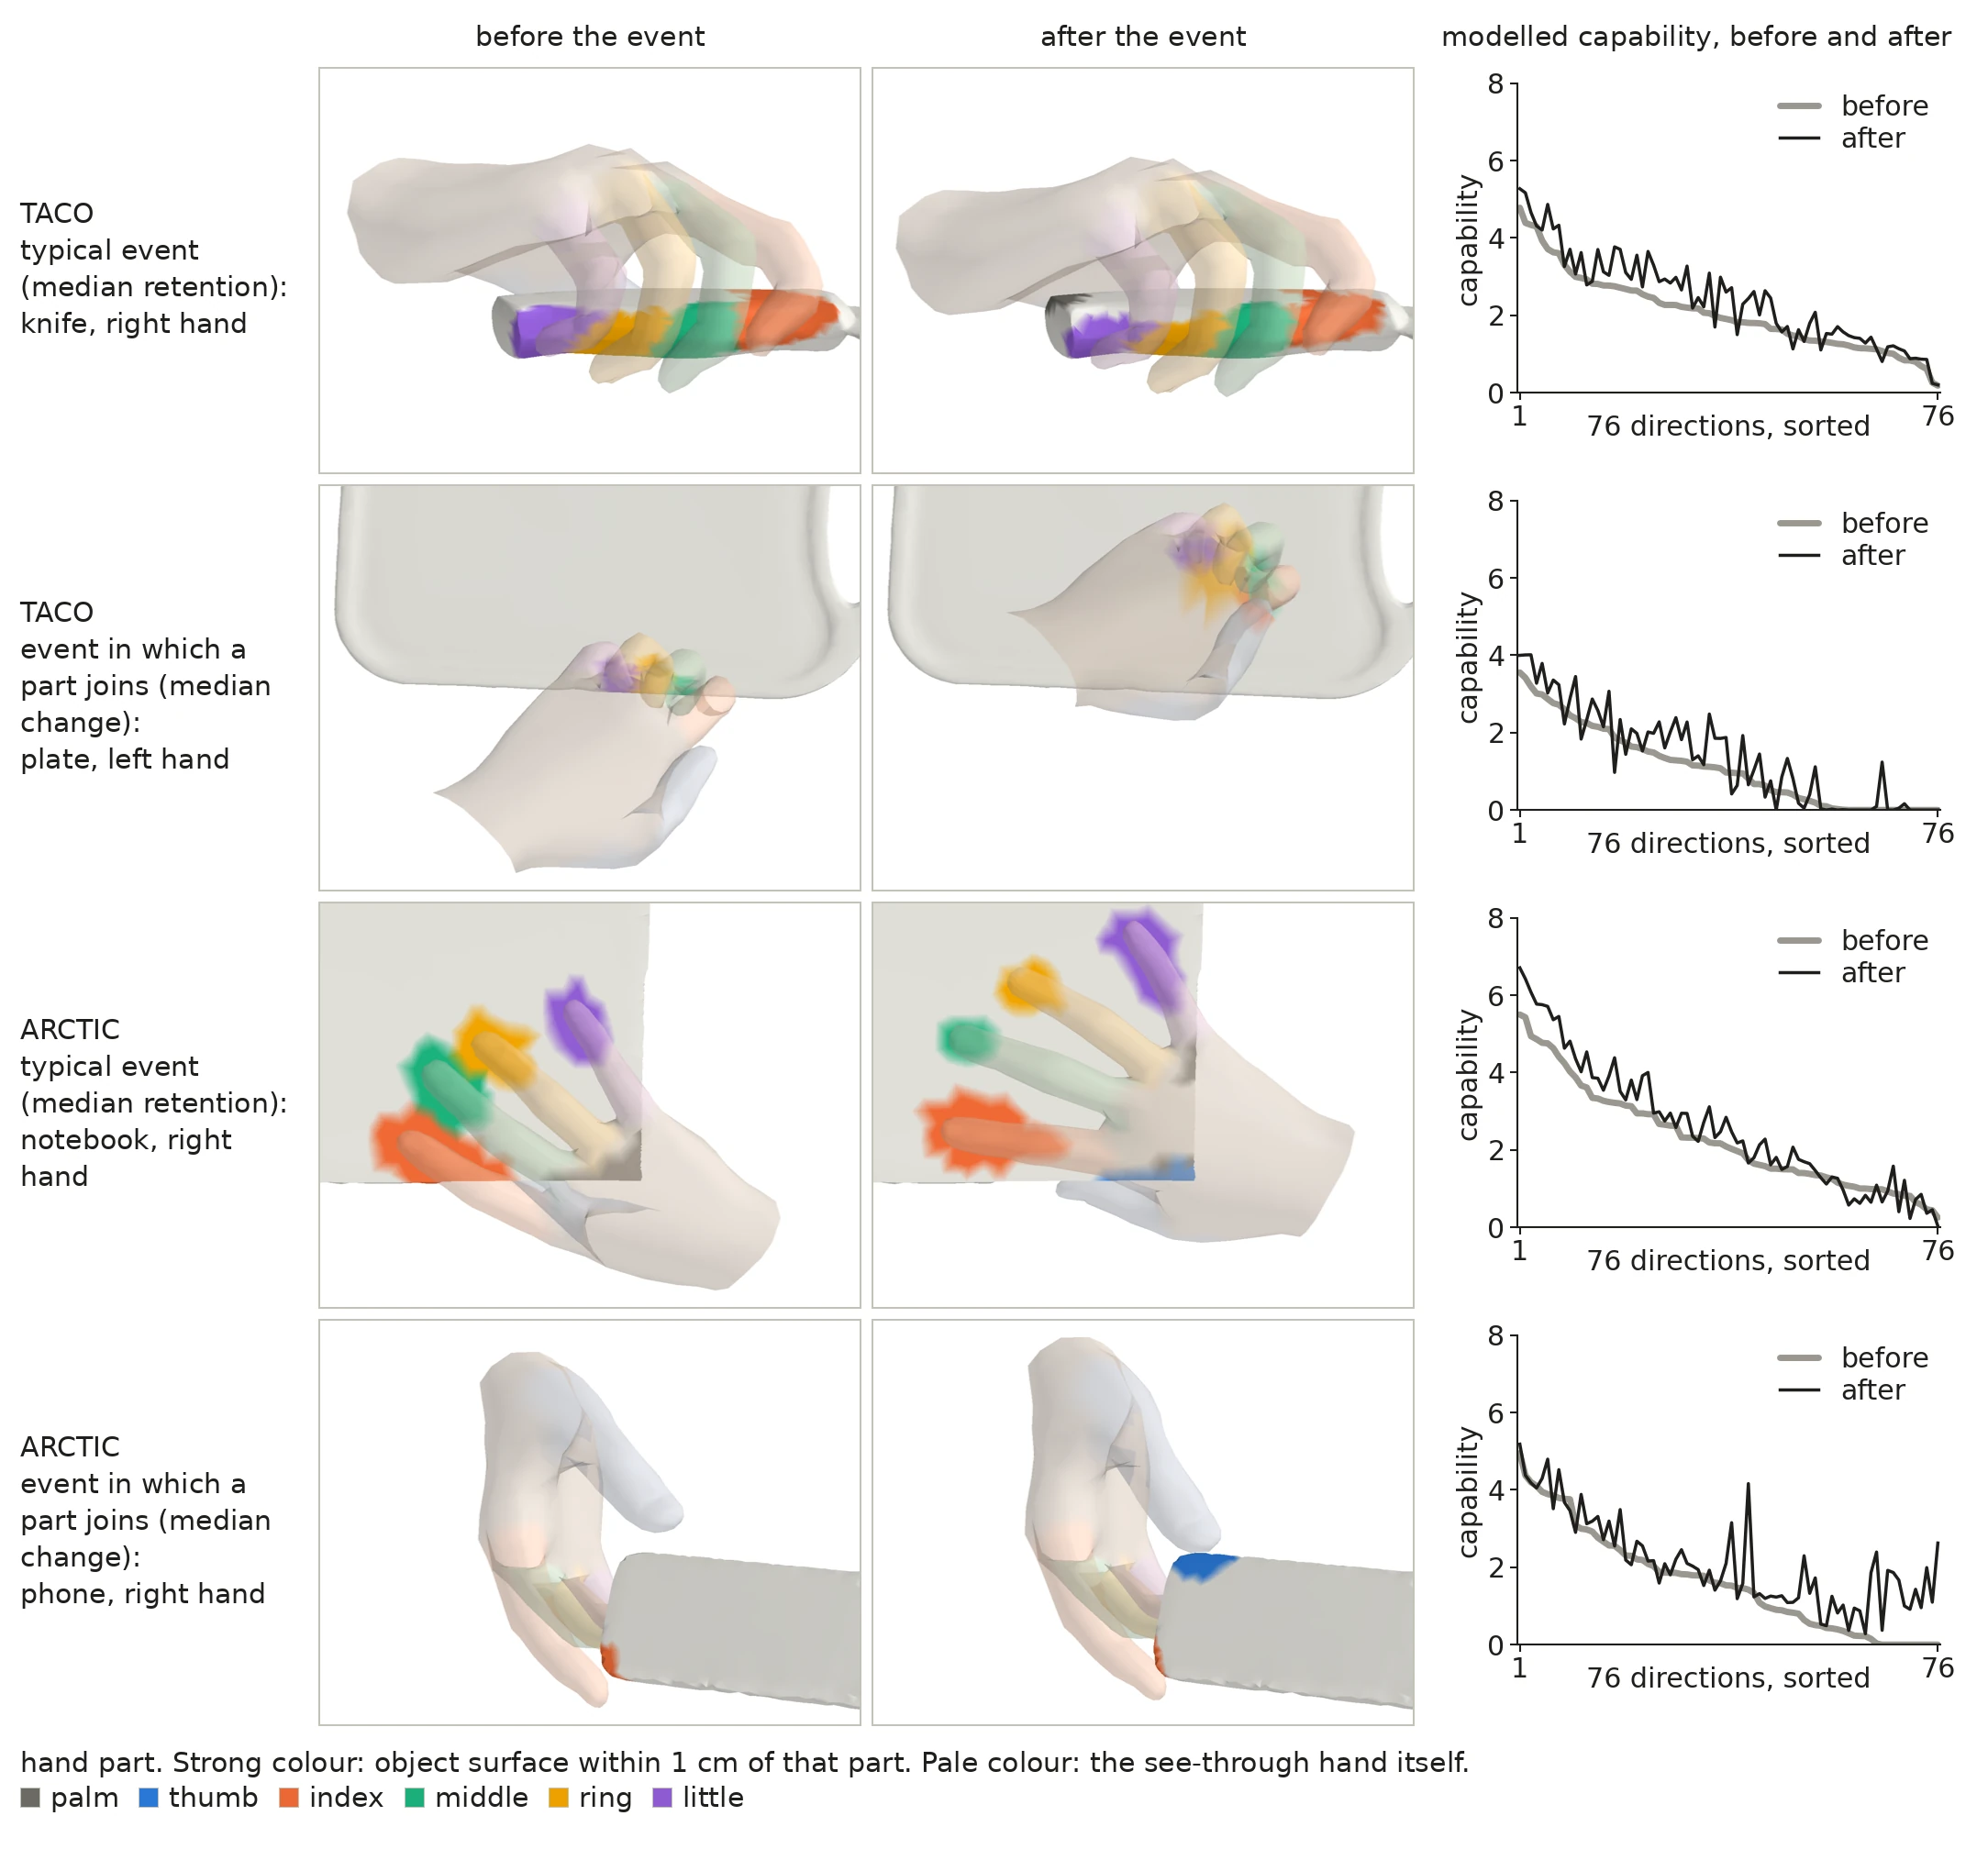
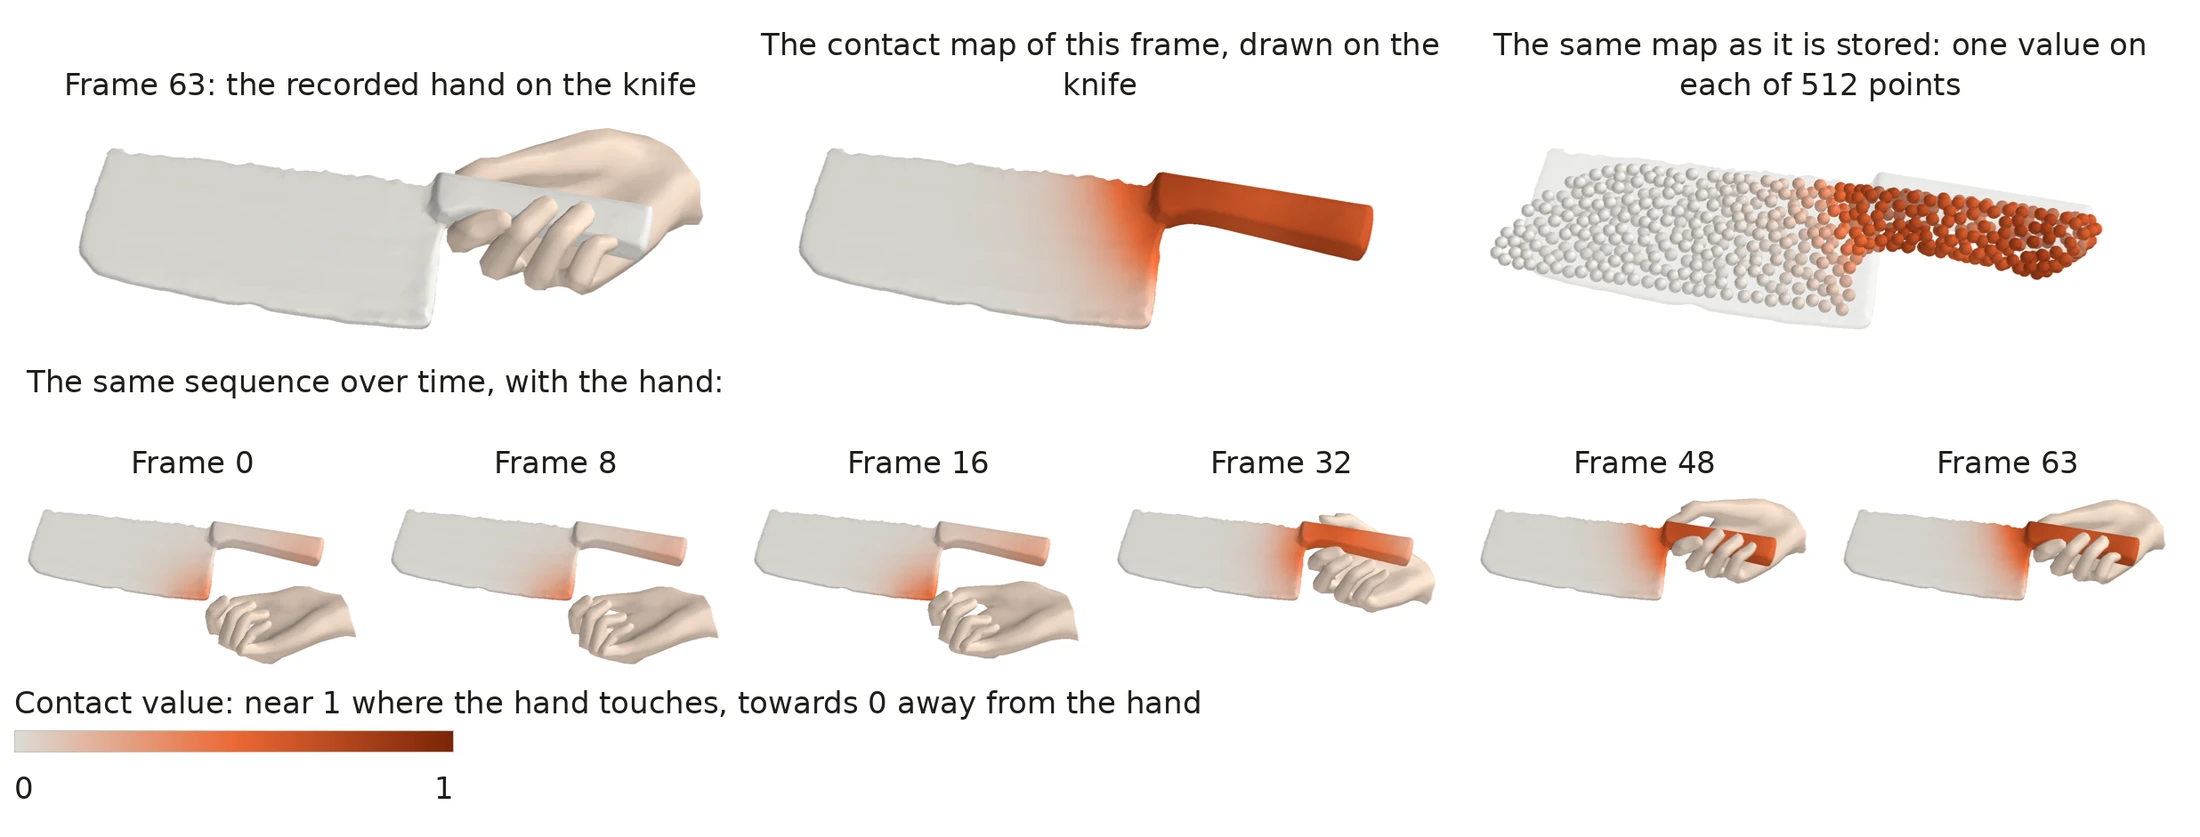
Choose an initial contact realization (first contact map s0), then model its evolution (C: contact maps; G: object geometry; τ: object motion). On TACO, a learned model that evolves the true first map clearly beats holding it (error 3.48 → 1.82); on ARCTIC and OakInk2 the difference is not distinguishable from zero, although contact still changes there.
TACO ARCTIC OakInk2 Source: hold-versus-evolve comparison