
Unghui Nam
Graduate Student at Seoul National University
- Robot Learning
- Manipulation Data
I am a graduate student working on robot learning and manipulation data. I am currently advised by Byonghyo Shim. I have also had the privilege of working with Kyuhong Shim and Yongseok Lee. I am interested in building reliable and efficient learning systems for robots.
News
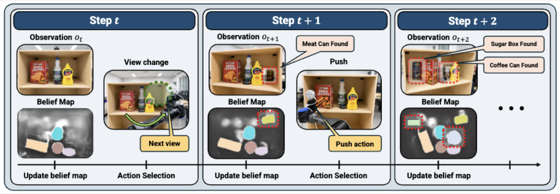
- 2026 Our paper, Learning Decomposed Visibility for Efficient Active Exploration of Cluttered Scenes, is accepted to the Conference on Robot Learning (CoRL) 2026!
- 2026 Our paper, Adaptive Capacity Allocation for Vision Language Action Fine-tuning, is accepted to the IEEE International Conference on Robotics and Automation (ICRA) 2026!
Publications

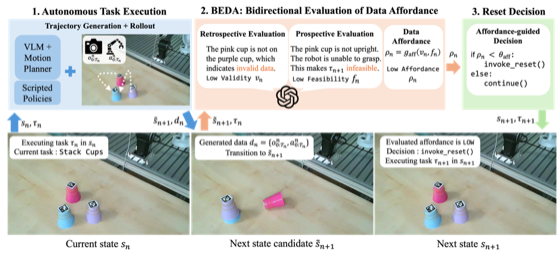
Scalable Autonomous Robotic Data Collection via Data Affordance-Guided Intervention
Under Review
* Equal contribution. † Corresponding author.
Projects
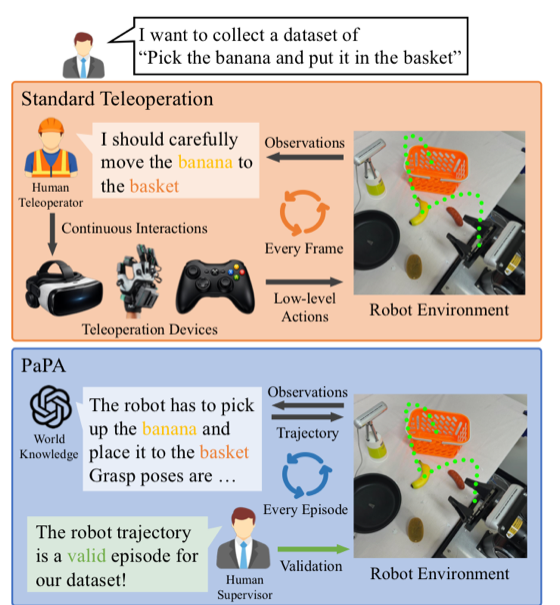
PaPA: Pick-and-Place Anything
A robotic data collection framework that grounds open-vocabulary language instructions into explicit geometric representations with vision-language models, autonomously generating manipulation trajectories and reducing human effort to lightweight post-hoc verification.
DexCORE
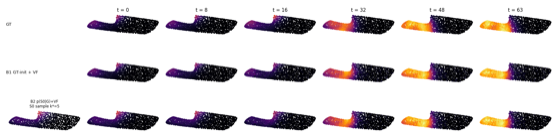
A study of hand-object contact generation: what varies in a dense contact trajectory, what actually matters in it, and how to model what matters. Contact trajectories are cast as an initial grasp mode plus a structured temporal evolution, with evidence from TACO, ARCTIC and OakInk2.
Shappy
A quadruped research journal in two versions: building Pupper v3 and training locomotion policies in simulation before bringing them to the robot, then designing a new Mini Cheetah-size quadruped, starting with leg design and stiffness comparisons.